HTR-V
Advanced space robotics for planetary exploration and in-orbit servicing
Profile
Legal Name
HELLENIC TECHNOLOGY OF ROBOTICS VENTURES S.A.
Tagline
Advanced space robotics for planetary exploration and in-orbit servicing
Details
HTR-V is a Greek robotics engineering company specialising in advanced autonomous systems for demanding terrestrial and space applications. Building on decades of experience in field robotics, HTR focuses on two principal space domains: planetary exploration and in-orbit servicing, developing robotic platforms, mechanisms, actuation and control systems for operation in harsh and unstructured environments. Its capabilities include autonomous ground vehicles, robotic systems for satellite capture and servicing, terramechanics testing and advanced simulation tools. HTR has also developed and patented an all-metal, elastic variable-stiffness rover wheel for planetary mobility. The company has participated in numerous ESA and European R&D programmes, combining mechanical engineering, mechatronics, sensing, control and robotic autonomy to support next-generation exploration and orbital robotics missions.
Classification
Type
Private Company - SME
Size
Micro (2-10 employees)
Category
Enabling Technologies, Robotics & Autonomous Systems
Value Chain Position
Upstream
Map
An interactive map showing the organisation's location will appear here.
Send Message
Your Name
Your Email
Subject
Your Message (optional)
Send Message
Contact
Website
https://www.htr.gr
CONTACT Email
ktasos@htr.gr
CONTACT Phone
2108010033
Address
1 km Elafonisos-Panagia
Peloponnese
Greece
230 53
International Presence
Strategic Focus
Strategic Priorities: HTR’s strategic priorities focus on the development of advanced space robotics for planetary exploration and in-orbit operations, with particular emphasis on terramechanics, autonomous robotic vehicles and robotic arms. The company aims to advance robotic mobility systems for challenging extraterrestrial terrains, including rover platforms, proprietary wheel technologies and mobility solutions supported by modelling and testing of wheel–soil interaction. In parallel, HTR is strengthening its capabilities in autonomous navigation, robotic manipulation, mechatronics, embedded control, satellite servicing and docking technologies. A key priority is the maturation of these technologies from prototype to mission-ready hardware through in-house engineering, manufacturing and testing, supporting future lunar and planetary missions as well as in-orbit servicing applications. HTR also seeks to expand its participation in ESA and European space programmes and establish strategic industrial partnerships for the qualification, deployment and commercialisation of its robotic technologies.
Looking for Partnerships: HTR is interested in partnerships with entities active in terramechanics, planetary mobility and space missions, including research organisations, space agencies, mission integrators, upstream OEMs and technology providers. Areas of interest include joint development and validation of rover and mobility systems, wheel–soil interaction and terrain modelling, autonomous robotic vehicles, robotic arms and manipulation systems, as well as technologies for lunar and planetary exploration and in-orbit operations. HTR also seeks participation in collaborative R&D and demonstration missions where its robotic platforms, mobility technologies and engineering capabilities can be integrated, tested and qualified in mission-relevant environments.
Background
Established: 2023-09-27
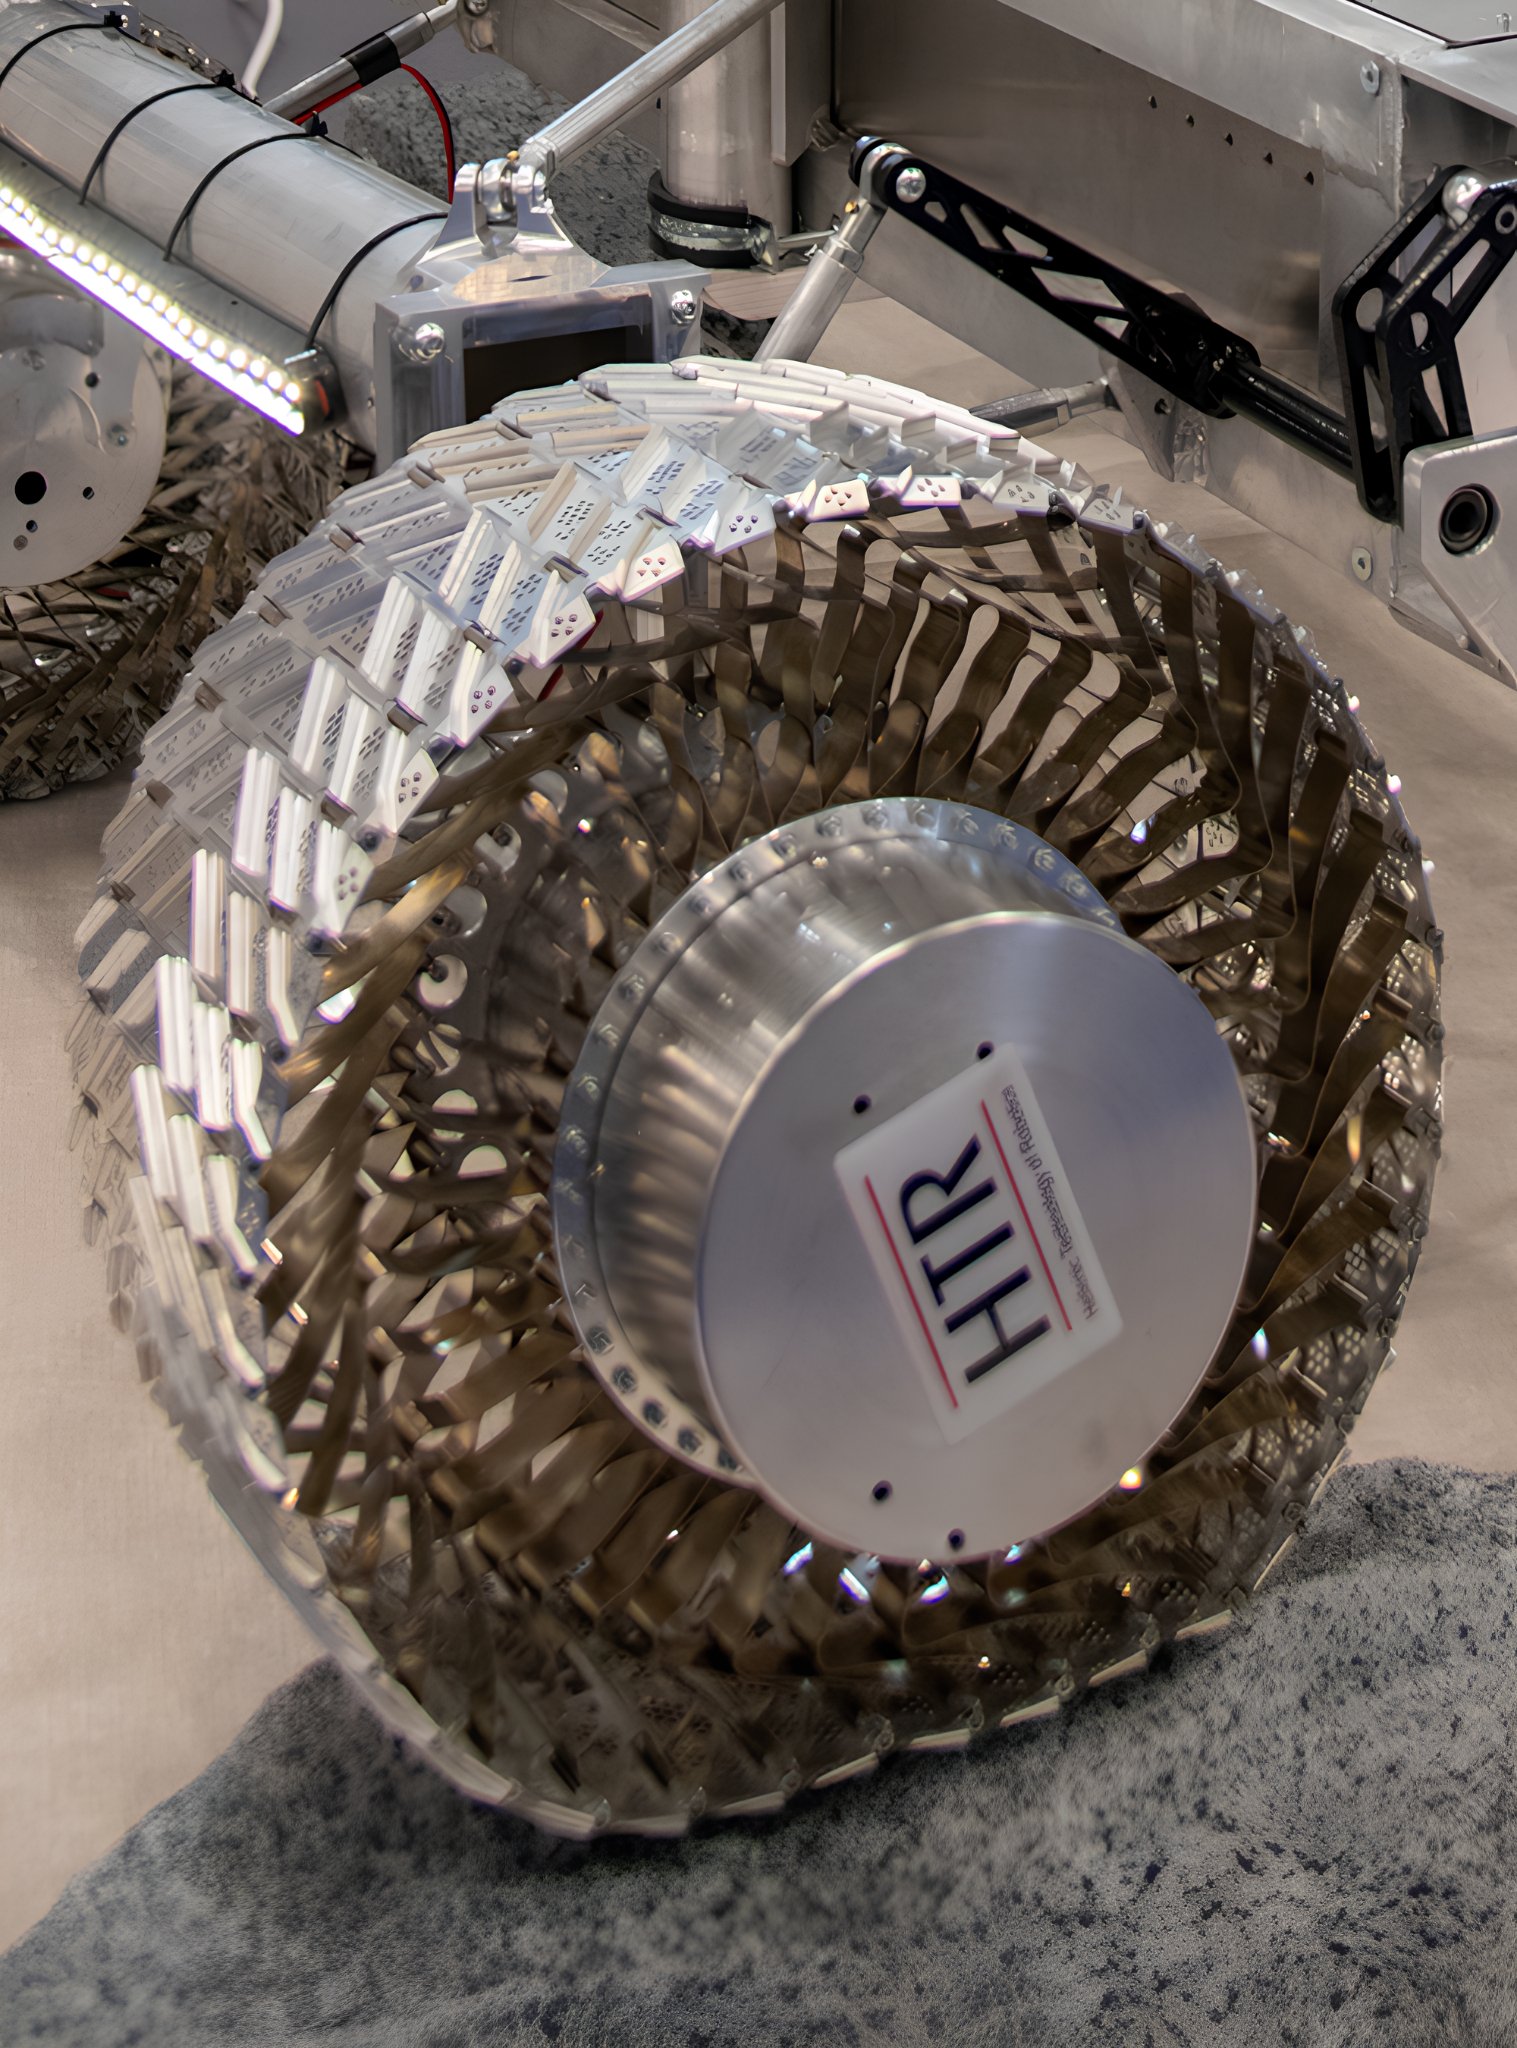
Projects & Missions: DUSTER & Solar panel cleaning on the Martian surface. The development addresses the design and prototype integration of a pump system able to compress the very thin (7 mbar) Martian atmosphere and then use it as compressed gas to clean the solar panels and other lander / rover components contaminated from Martian dust on the surface of the planet. Furthermore, the project requires the design and construction of a dedicated ultra-light robotic system that should be used to direct the cleaning nozzle over the panels. AWE & Adaptable Wheels for Exploration. HTR has spent a great effort to completely restudy and redesign the concept of wheels made from metal. Since the AWE idea consisted in wheels of variable stiffness, a design that permitted such feature had to be elaborated and demonstrated in operation. To this end, a caterpillar-type wheel has been chosen, where the caterpillar segments adapt on the ground using antagonistic springs. The result is an extremely robust wheel (no risk of permanent deformation over sharp, rocky ground) with a capacity to modify its stiffness (by a factor of 4), therefore permitting the wheel to have a very large contact area on soft soil while it can obtain a significantly smaller contact area on hard surfaces, contributing to power economy. PREDATOR & Pre-Development of a Launch Adapter Ring Gripper (On-going project). HTR manufactured a robotic system that is composed of a robotic arm/gripper and a testbed. Testbed is used to provide a motion of a non-cooperative satellite, and the robotic arm/gripper attempts to catch it under various angles of attack and speeds.
Key Customers: HTR’s key customers and partners include European Union institutions and programmes, the European Space Agency (ESA), leading European space-industry companies, and upstream space OEMs requiring advanced robotic mobility, manipulation and in-orbit servicing technologies. The company supports institutional and industrial customers through the development and supply of planetary rover systems, adaptable wheel technologies, robotic arms, docking mechanisms and autonomous robotic platforms, as well as related engineering, prototyping and testing services. HTR has contributed to ESA-supported lunar mobility activities, including the European Moon Rover System and RAPID programmes, and participates in European collaborative projects with space-industry partners addressing autonomous space operations and Space Situational Awareness.
Affiliations/Memberships: si-Cluster HASI
Facilities: HTR operates integrated R&D, prototyping, manufacturing and testing facilities for advanced robotics and space mobility systems. Its infrastructure includes dedicated test platforms for rover endurance, wheel–soil interaction, drawbar pull and slope-climbing performance, as well as locomotion testbeds using different soil types for realistic terramechanics evaluation. For in-orbit robotics, HTR maintains satellite approach and docking test setups, including a multi-DOF zero-gravity simulation table supported by end-to-end dynamic simulation capabilities. In-house production facilities combine CNC machining and advanced 3D printing, enabling rapid prototyping, small-batch manufacturing and iterative development from concept through engineering and flight-model hardware. HTR operates facilities in Athens and a dedicated laboratory in Lianokladi, Lamia.
Application Domain
Follow
Twitter / X